AUTONOMOUS
ENTRY
INTO CONTAINER.
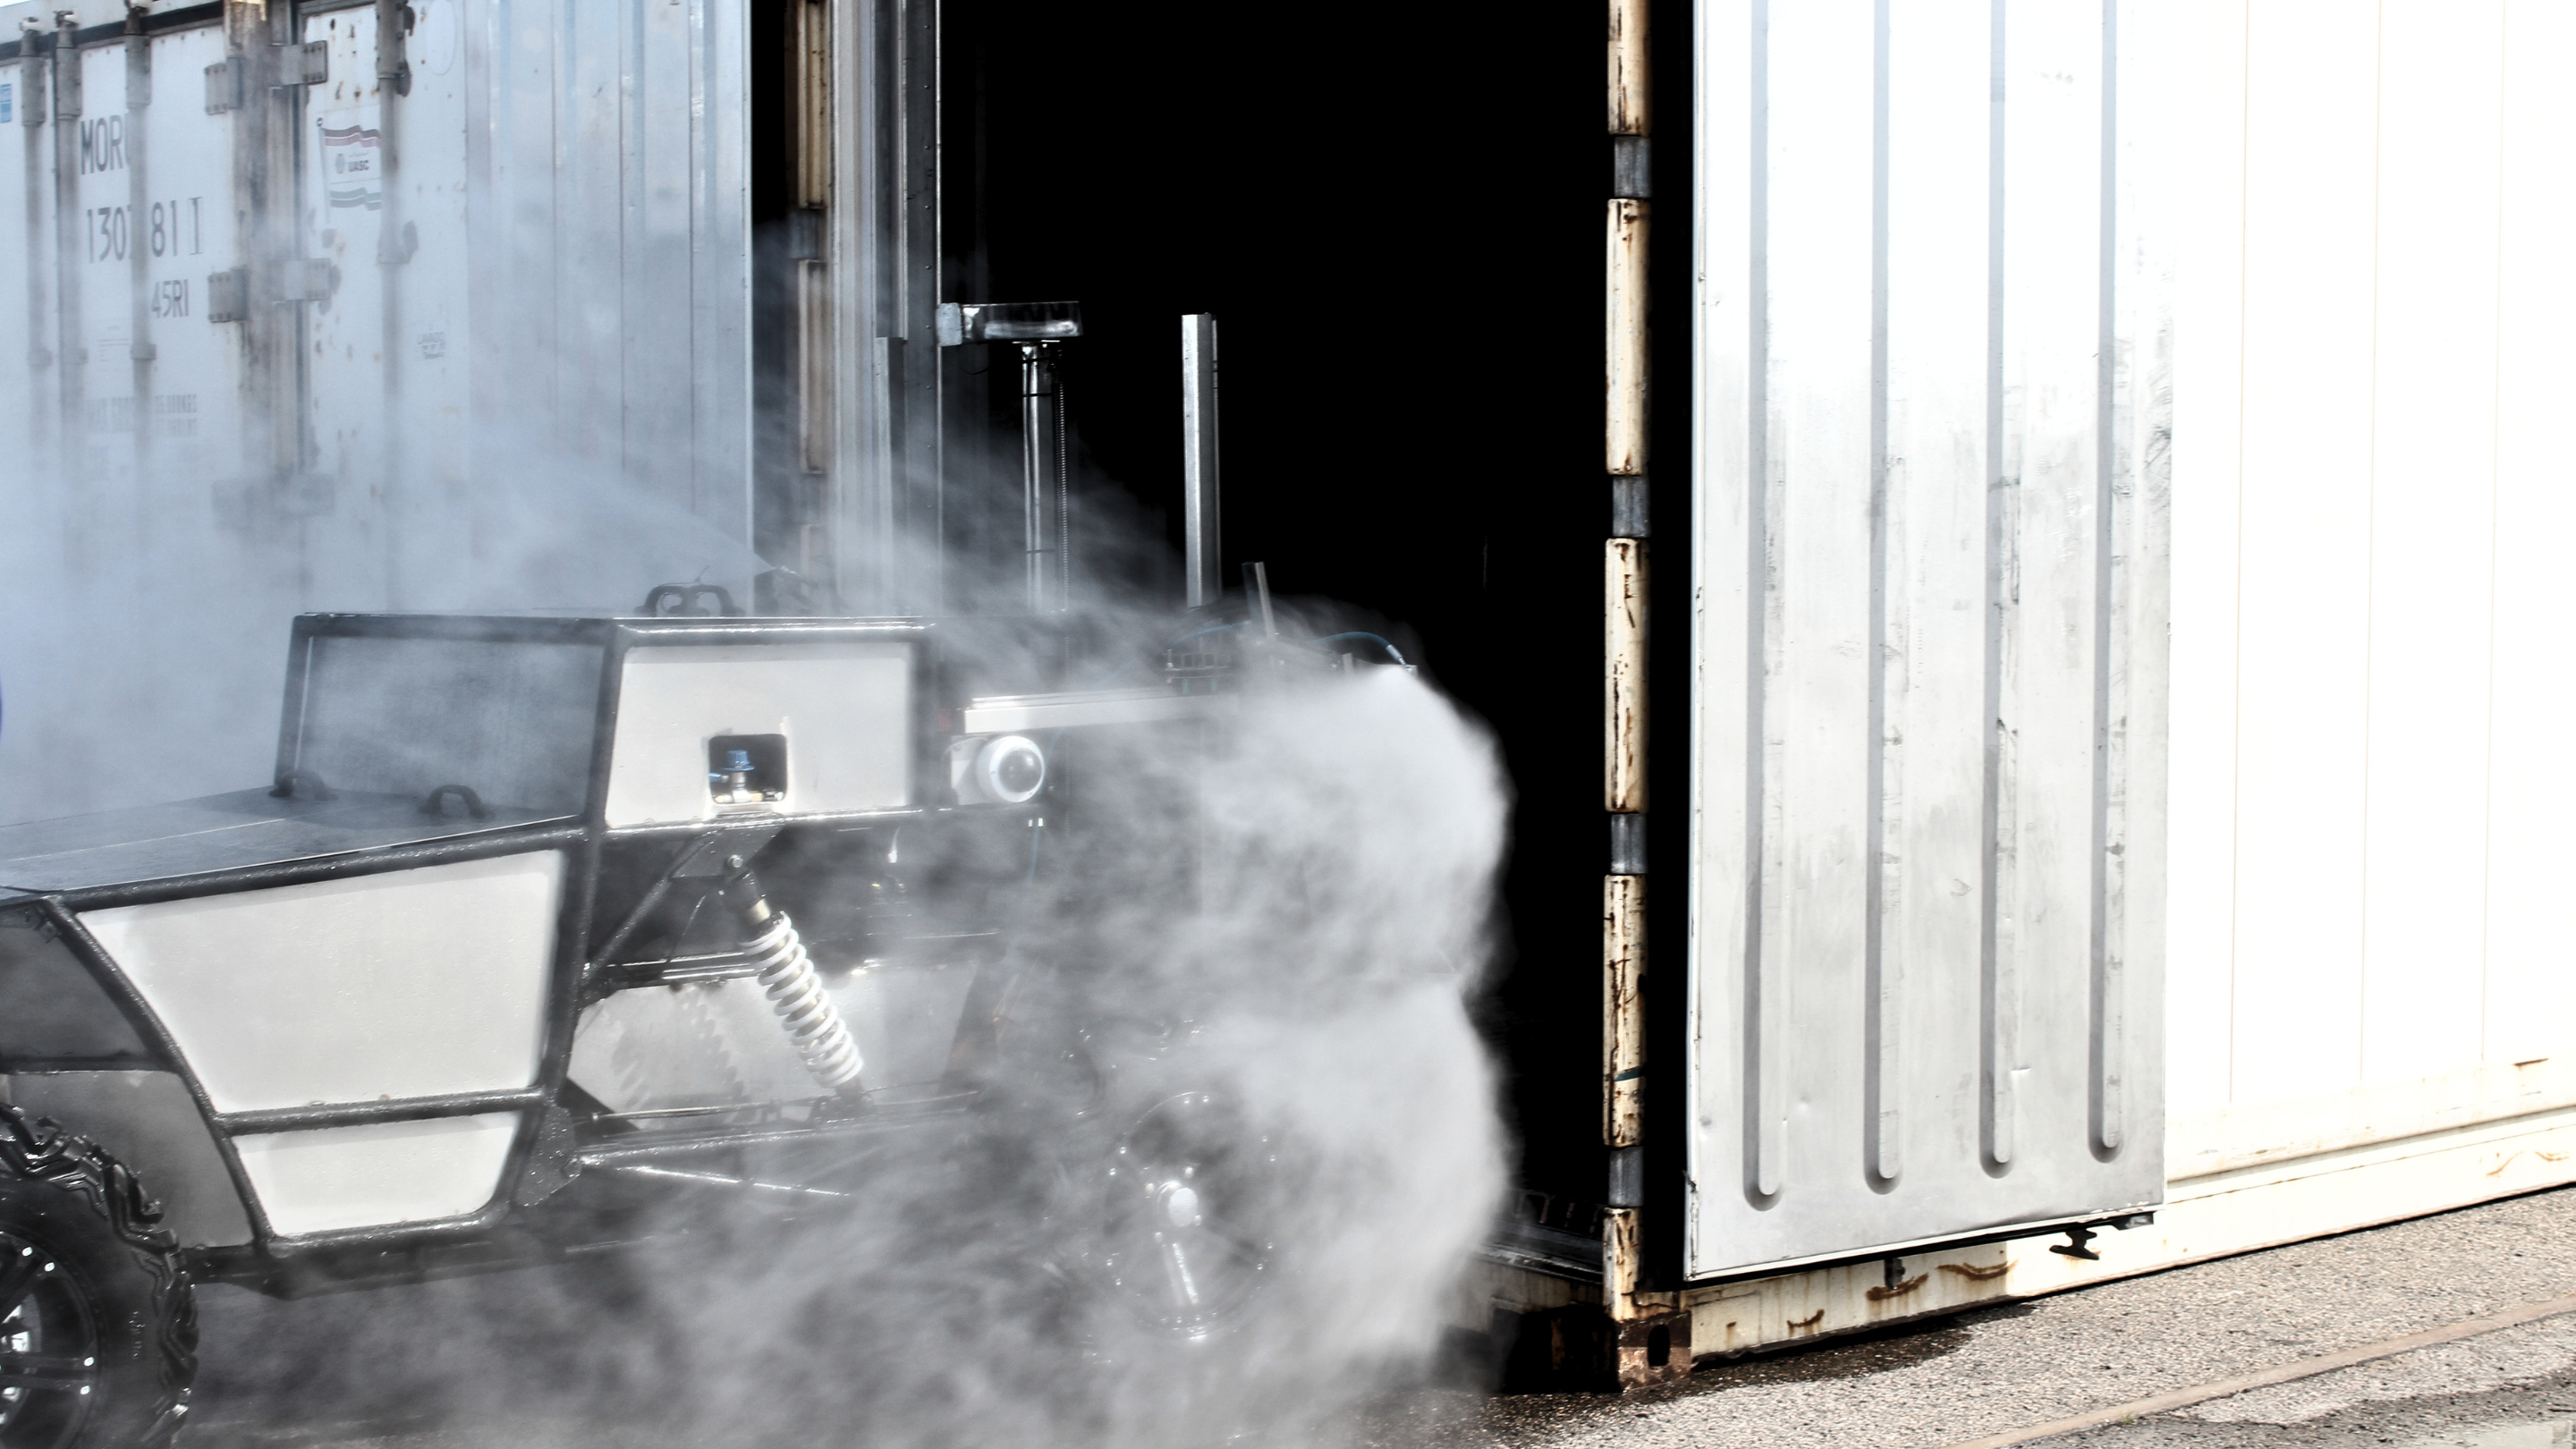
Cleaning starts as the robot enters the container. With the wash frame raised, the ceiling and upper walls are cleaned during the inbound pass.


Robotic interior container cleaning, engineered for terminal operations. Supervised autonomy with no personnel entering the container during the wash.
Box Cleaner cleans the container on both the inbound and return pass. Upper surfaces are cleaned on the way in, before the system repositions and cleans the floor and lower walls on the way out. Compatible with both reefer and dry containers.
Cleaning starts as the robot enters the container. With the wash frame raised, the ceiling and upper walls are cleaned during the inbound pass.
As Box Cleaner moves toward the far end, the wash system follows the full length of the container, cleaning the ceiling and upper walls. This pass generally uses a lower-pressure setting.
At the bulkhead wall, cleaning assembly repositions for the return wash, while cleaning the bulkhead wall simultaneously
On the return pass, the floor and lower walls are cleaned while the spray pattern continuously directs water and debris toward the container opening.
This creates a consistent washout compared with manual single-nozzle cleaning, where water and debris can repeatedly be pushed back into already cleaned areas. The faster process also leaves less time for wooden dry-container floors to absorb water.
Box Cleaner is delivered as a managed cleaning service. There is no machine purchase. Commercial terms are tied to completed container washes and the expected operating volume at each terminal.
Terminals already manage container services on a unit basis: washing, repairs, lifts and other activities are associated with individual containers. Robotic cleaning follows the same logic.
Box Cleaner is supplied as part of the cleaning service rather than sold as capital equipment.
Routine charges follow completed cleaning volume, subject to the commercial volume agreed for the deployment.
MCS handles maintenance, normal wear parts, technical support and continued software development as part of the service.
Box Cleaner is introduced into the terminal’s existing wash operation, replacing the manual cleaning task without redesigning the wider container flow.
Observe the existing wash process, container flow, volumes, container mix and operational constraints before designing the deployment.
Define wash positions, staging, traffic separation, the controlled operating area, ramp, hose routing and utilities.
Box Cleaner, pump and supporting equipment are installed and connected. Water, power, connectivity and emergency systems are tested before live washing begins.
Representative dry and reefer containers are processed in the live operation while cleaning quality, cycle time, water use and agreed KPIs are measured.
The wash area can be configured around multiple staged containers. Box Cleaner returns from one completed wash, traverses inside the controlled area and aligns with the next container.
Every deployment follows a defined customer journey. Site requirements, operating conditions and success criteria are agreed before the pilot begins, creating a clear path from first assessment to routine operation.
Confirm the fundamental site conditions required to operate Box Cleaner.
MCS reviews how containers currently move through the wash operation and where the system should be integrated.
Before deployment, MCS and the terminal agree what the pilot should demonstrate and how performance will be measured.
Box Cleaner is commissioned and operated on representative containers in the terminal's real operating environment.
Once the operating case is validated, the system transitions into routine pay-per-wash operation and capacity can grow with demand.